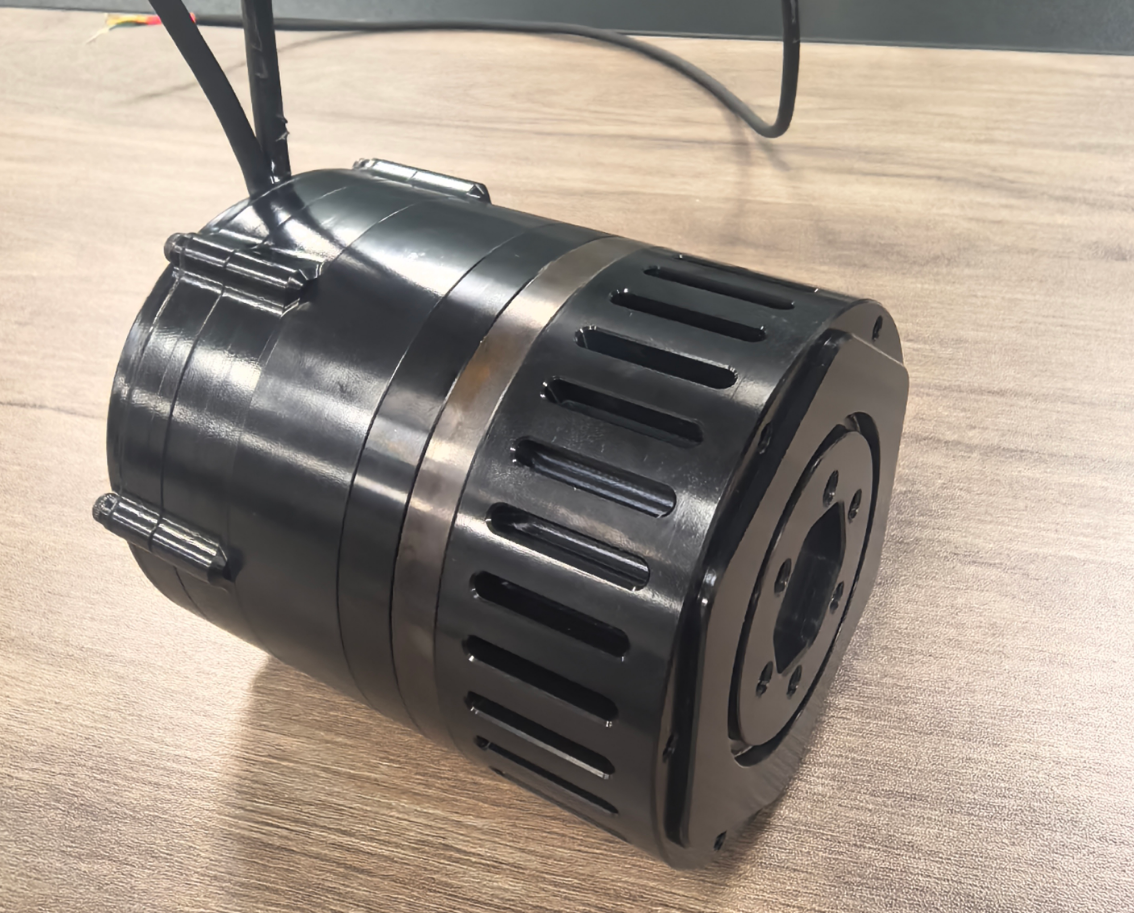
Harmonic vs Cycloidal vs Planetary: Engineering Guide to Gearbox Selection for Robot Joints
A systematic comparison of harmonic, cycloidal (RV) and planetary gearboxes for robot joints across backlash, torque density, stiffness, efficiency and service life, with selection recommendations by joint load class.
Why the Gearbox Defines the Joint
In a robotic joint actuator, the gearbox — not the motor — usually sets the limit on accuracy, payload and service life. A typical electric joint is a torque-limited system: the motor produces its peak torque at high speed, and the reduction stage converts that speed into usable joint torque. The choice of reduction stage therefore determines three things at once: how much torque fits into a given diameter, how precisely the joint can be positioned, and how the joint behaves when it is back-driven or impact-loaded.
Three reducer families dominate rotary robot joints today: strain-wave (harmonic) drives, cycloidal / RV gears, and precision planetary gears — increasingly in hybrid two-stage arrangements. The table below summarizes where each wins.
| Parameter | Harmonic (strain wave) | Cycloidal / RV | Precision planetary |
|---|---|---|---|
| Backlash | 0–20 arcsec (near-zero, preloaded) | <1 arcmin | 1–8 arcmin (low-backlash class) |
| Torque density | Moderate | Highest (2–4× harmonic) | Moderate–high |
| Torsional stiffness | Moderate (flexspline-limited) | Very high | High |
| Efficiency | 70–90% | 85–95% | 90–97% |
| Mass / compactness | Very light, flat pancake form | Heavy, compact radial | Light, modular |
| Typical ratio range | 50:1–160:1 (single stage) | 30:1–190:1 | 3:1–10:1 per stage |
| Weak point | Flexspline fatigue life | Mass, inertia, cost | Backlash under preload wear |
Matching the Gear to the Joint
High-torque joints (hip, knee, shoulder, base azimuth). These joints see the largest gravity and impact loads, so torque density and torsional stiffness dominate. Cycloidal or RV gears are the classical choice for industrial robots precisely because they offer 2–4× the torque density of harmonic drives with very high stiffness. The penalty is mass at the distal end and reflected inertia — acceptable in a hip, painful in a wrist. For a 30–80 Nm continuous joint, an RV-class reducer paired with a high-torque-density BLDC motor and a 48 V servo drive rated for 20 A+ peak current is a proven architecture.
Agile and distal joints (wrist, elbow, ankle, gripper yaw). Here the joint itself is part of the moving mass, so the harmonic drive's flat, lightweight pancake form factor wins. Modern humanoid designs favor QDD (quasi-direct-drive) actuation in distal joints: low gearing ratios combined with high-torque, low-speed BLDC motors and FOC control, which improves impact robustness and backdrivability for contact-rich tasks. Where positioning precision matters more than compliance — for example, a camera or antenna pointing axis — a harmonic stage with its near-zero backlash remains the simplest way to get arcsecond-class repeatability.
Cost-optimized, high-volume joints. Precision planetary gears are the workhorse wherever volume economics matter and moderate backlash is acceptable. Modern low-backlash planetary stages (1–3 arcmin) with helical teeth reach torque densities that were harmonic territory five years ago, at a fraction of the cost. Many practical joint modules use a hybrid: a planetary first stage for bulk reduction and thermal spreading, followed by a harmonic or cycloidal output stage for precision.
| Joint class | Continuous torque | Recommended reducer | Typical bus interface |
|---|---|---|---|
| Hip / knee / shoulder | 30–120 Nm | RV / cycloidal, or two-stage planetary | EtherCAT / CANopen |
| Elbow / wrist | 8–30 Nm | Harmonic (strain wave) | CANopen / EtherCAT |
| Ankle / gripper yaw | 2–10 Nm | Harmonic or QDD (low-ratio) | CANopen |
| Antenna / sensor pointing | 1–10 Nm | Harmonic (near-zero backlash) | RS-422 / CANopen |
Selection Checklist
Beyond the gear family itself, four practical factors decide whether a joint module performs in the field:
- Rated vs peak torque derating. Size the reducer for continuous torque at the actual duty cycle, and verify the peak-torque duration (typically <3 s) against the drive's current limit — not the motor's nameplate.
- Backlash is a system property. Encoder placement matters: a joint with an output-side encoder tolerates 2–3× more gearbox backlash for the same absolute accuracy, which can move a design from harmonic to planetary economics.
- Thermal path. Joint modules at 50–150 W continuous dissipation need a deliberate conduction path through the housing; a compact harmonic joint with no thermal path will derate 30% or more.
- Integration overhead. An all-in-one joint module — motor, reducer, drive and encoder pre-integrated and tested — eliminates the motor-gearbox alignment work that consumes weeks of engineering time in custom builds.
For teams evaluating joint actuation platforms, Repunite's integrated joint modules cover the mid-torque range with factory-integrated motor + reducer + drive + encoder units: the JTM-50 series for compact joints, the JTM-90-282 (48 V, 282 W, 24.5 A peak, CANopen/EtherCAT) for elbow/wrist-class axes, and the JTM-147 for high-torque shoulder/knee-class joints. Matching JGASD servo drives and JGSM servo motors are available for custom joint builds that need a separately packaged architecture.