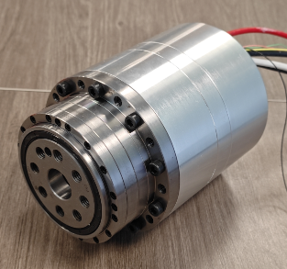
Cycloidal Pinwheel Joint Motor 91 · 660W with Brake
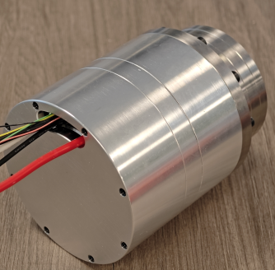
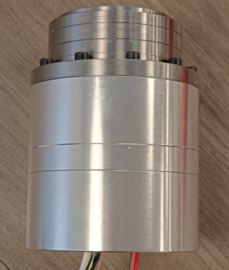
The cycloidal pinwheel joint motor (with brake) integrates a frameless torque motor, cycloidal pin-wheel reducer, encoder, and a 24V brake with backlash under 3 arcmin. Widely used in robotic arms, humanoid robots, and multi-legged robots.
The cycloidal pinwheel joint motor (with brake) is a highly modular and integrated actuator incorporating a frameless torque motor, a cycloidal pin-wheel reducer, an encoder, and a 24V brake. The reducer delivers backlash under 3 arcmin and 125 N-m rated torque, giving high repeatability and shock resistance; the power-off brake holds the output position for fail-safe vertical-axis applications. Operating temperature is -40 to +65 degrees C. Widely used in robotic arms, humanoid robots, and multi-legged robots.
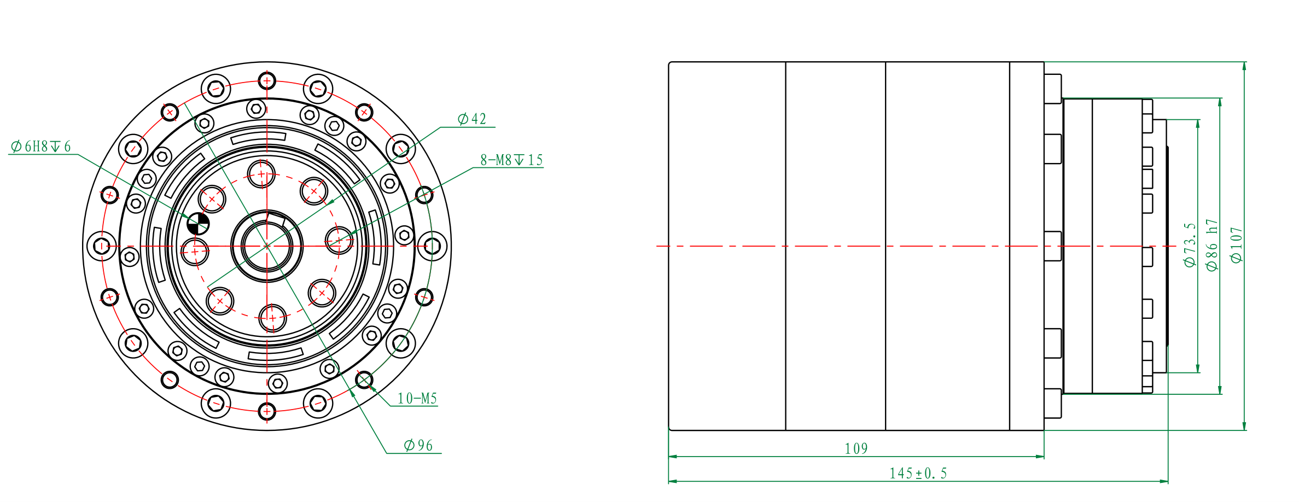
Key Features
- Rated Power: 660W
- Backlash: <3 arcmin
- Reducer Rated Torque: 125N·m
- Brake: 24V power-off brake
- Operating Temperature: -40℃ to +65℃
Technical Specifications
| Rated Voltage | DC 24V |
| Rated Power | 660W |
| Rated Speed (Motor) | 3000rpm |
| No-load Speed (Motor) | 4000rpm |
| Rated Torque (Motor) | 2.1N·m |
| Peak Torque (Motor) | 6.3N·m |
| Rated Current | 31A |
| Peak Current | 105A |
| Pole Pairs | 14 |
| Torque Constant | 0.067N·m/Arms |
| Gear Ratio | 1:51 |
| Backlash | <3 arcmin |
| Rated Torque (Reducer) | 125N·m |
| Rated Speed (Output) | 59rpm |
| Rated Torque (Output) | 91N·m |
| Peak Torque (Output) | 273N·m |
| Brake | 24V brake (X03 brake input brk+/brk-) |
| Operating Temperature | -40℃ to +65℃ |
| Power Interface | X01 DC voltage input (U/V/W) |
| Encoder Interface | X02 encoder (5V/GND/A/B) |